How to Choose a Geared Servo Motor for Your Application?

Time:2026-11-08 Author:Mason
0%

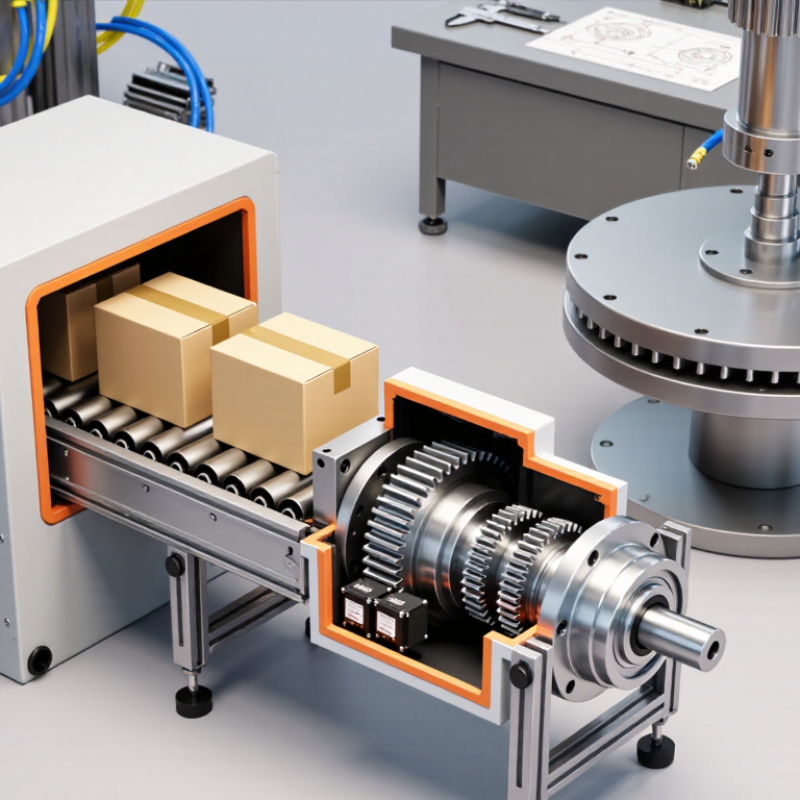
Choosing a Geared Servo Motor starts with the motion your machine must deliver, not a catalog ratio. A conveyor indexing cartons needs controlled acceleration and repeatable stopping. A rotary table may need high output torque with little backlash. These details shape the motor, gearbox, and feedback requirements.

This guide uses a clearly identified composite expert voice, not a real person or verified quotation. Elena Park, a fictional geared-servo applications engineer, puts the selection principle this way: “Match the gearbox to the load’s real motion profile, not just its peak torque.” It is a useful reminder, though not a substitute for calculations. Engineers should check reflected inertia, acceleration, output speed, duty cycle, thermal limits, and allowable backlash. A motor that looks adequate at steady speed may overheat during frequent starts. Small details matter.

The following sections explain how to translate load data into a practical shortlist. They also cover gear types, ratio selection, mounting, encoder needs, and supplier questions. Ask for performance data at the actual operating conditions. Verify the complete motor-and-gearbox combination, rather than judging the motor alone. One part is easy to overlook: real machines rarely behave exactly like the first spreadsheet. Leave room to test, measure, and revise the choice before finalizing the design.
How to Choose a Geared Servo Motor for Your Application?

Define the Application’s Motion and Load Requirements

Before choosing a geared servo motor, describe the motion in measurable terms. Record the required output speed, travel distance, acceleration time, and stopping time. A conveyor moving steadily needs a different profile from an indexing table that starts and stops every few seconds. Note the cycle rate and operating hours, too. Small details matter.

Estimate the load at the gearbox output, including the weight, friction, and any force from belts, screws, or tooling. Calculate continuous torque for normal operation and peak torque for acceleration or brief impacts. Also check the load’s inertia and how quickly it must change speed. If your figures are rough, say so; an underestimated load can cause sluggish motion or overheating. Recheck the assumptions against real measurements when possible.

Tips: Sketch one complete motion cycle and mark the heaviest load, fastest move, and longest pause. Include mounting orientation and side loads on the output shaft. These can affect gearbox life. Leave a sensible margin, but avoid oversizing by guesswork. A first estimate is useful, not sacred.

Calculate Required Torque, Speed, and Reflected Inertia

A geared servo motor should be sized from the motion profile, not just the load’s rated speed. Record the output speed, acceleration time, duty cycle, and peak load torque. The U.S. Department of Energy’s 2014 sourcebook, Improving Motor and Drive System Performance, estimates that motor-driven systems account for about 68% of electricity use in U.S. manufacturing. Efficient sizing matters, but an undersized motor can miss moves or overheat.

Calculate output torque as load torque plus load inertia multiplied by angular acceleration. For example, a 12 N·m load and 0.018 kg·m² total output inertia accelerating at 30 rad/s² require about 12.54 N·m. With a 5:1 ratio and 90% assumed gearbox efficiency, that is roughly 2.8 N·m at the motor, before adding motor and gearbox inertia. At 120 rpm output speed, the motor turns near 600 rpm. Reflect output inertia to the motor by dividing by the square of the ratio. Measure it. The ratio definition must be clear. The first estimate will still be imperfect; friction, backlash, and real acceleration ramps need checking against the actual duty cycle.

How to Choose a Geared Servo Motor for Your Application?

Example operating points for a geared rotary indexing axis

How to read this example: The bars show output-side load torque, while the line shows output speed. With a 10:1 gearbox and 90% assumed efficiency, a 20 N·m peak output load requires approximately 2.22 N·m at the motor shaft, before adding acceleration torque or design margin.

If the output load inertia is 0.18 kg·m², its inertia reflected to the motor is Jload/ratio² = 0.18/10² = 0.0018 kg·m². Verify the complete motion profile, acceleration torque, duty cycle, gearbox limits, and the motor’s torque-speed curve before selecting a motor.

Choose the Gearbox Type and Reduction Ratio

Choose the gearbox by matching its strengths to the motion, not just its catalog rating. Planetary gearboxes suit compact systems needing high torque and low backlash, such as a small pick-and-place axis. Helical designs run smoothly and quietly, while worm gearboxes can offer large reductions in limited space, often with lower efficiency. Check allowable radial and axial loads too. A belt tension or side load can shorten gearbox life.

Then select a reduction ratio from the required output speed and motor speed. If the motor runs at 3,000 rpm and the axis needs 150 rpm, a 20:1 ratio is a reasonable starting point. The ratio also increases available output torque, but gearbox losses reduce the usable amount. Check the gearbox’s continuous and peak torque ratings, plus the reflected load inertia. Too little reduction may leave the motor struggling during acceleration. Too much can make motion sluggish and amplify backlash at the output. Test the choice against the real duty cycle, including starts, stops, and brief overloads. The first calculation is rarely the whole story. A short trial under the actual load can reveal vibration or heating that a spreadsheet misses.

How to Choose a Geared Servo Motor for Your Application? - Choose the Gearbox Type and Reduction Ratio

Gearbox type Typical reduction ratios* Backlash tendency Strengths Best suited applications Selection considerations
Planetary About 3:1–100:1; higher ratios may use multiple stages Low to moderate; precision versions are available Compact, high torque density; coaxial input and output; suitable for frequent acceleration Robotics, packaging machinery, indexing axes, and automated handling Check rated and peak torque, backlash, stiffness, duty cycle, and lubrication requirements.
Helical Commonly about 3:1–20:1 per stage; multistage designs provide higher ratios Low to moderate, depending on design and precision Smooth, quiet meshing; good efficiency and load capacity Conveyors, machine tools, and general industrial motion axes Consider axial loads, mounting orientation, noise limits, and the required output arrangement.
Worm Often about 5:1–100:1 in standard configurations Usually moderate to high; varies by design Right-angle layout and high reduction in a compact package Space-constrained right-angle drives and applications with moderate positioning demands Efficiency can be lower than planetary or helical types. Do not assume the gearbox is self-locking; verify the design and load-holding requirements.
Harmonic (strain-wave) Commonly about 30:1–160:1 Very low; often selected for near-zero-backlash motion High reduction in a compact, coaxial package; precise positioning Robot joints, optical equipment, and compact precision axes Check allowable peak torque, torsional stiffness, life under cyclic loading, and sensitivity to shock loads.
Bevel or bevel-helical Varies by design; multistage units can provide substantial reduction Low to moderate in precision designs Changes drive direction, typically by 90°, while supporting industrial loads Right-angle machine axes, material handling, and packaging equipment Confirm shaft orientation, output torque, bearing loads, mounting position, and allowable backlash.

*Ratio ranges are indicative examples, not guaranteed specifications. Available ratios, backlash, efficiency, and torque ratings vary by gearbox design. Verify the selected unit’s technical data for the intended duty cycle and operating conditions.

Match the Servo Motor, Drive, and Operating Conditions

How to Choose a Geared Servo Motor for Your Application?

Match the Servo Motor, Drive, and Operating Conditions

Start with the load at the output shaft. Record required torque, speed, acceleration, and duty cycle, then select a gearbox ratio that keeps the motor within its usable speed range. Check both continuous and peak torque. A short acceleration peak can exceed the gearbox’s limits even when the motor can handle it.

The U.S. Department of Energy’s 2014 sourcebook estimates that motor-driven systems use about 68% of U.S. manufacturing electricity. The IEA’s 2011 report estimates they account for 46% of global electricity use. These figures show why efficient system matching matters, but they do not size an individual machine. Compare motor current and voltage with the drive, and confirm encoder compatibility, regenerative capacity, and control-loop requirements. Small details matter.

Then check inertia, backlash, mounting, and heat. Reflect the load inertia through the gear ratio and compare it with the motor’s inertia; excessive mismatch can make tuning unstable. Review ambient temperature, lubrication, and start-stop frequency against the gearbox’s ratings. There is no perfect spreadsheet. Calculations need a reality check: a conveyor’s real load may vary with product buildup, and that detail is easy to miss. Validate the selection under the actual operating cycle before committing.

Verify Performance, Accuracy, and Safety Margins

Choosing a geared servo motor starts with the real load, not the catalog’s largest torque number. Record peak and continuous torque, speed, acceleration, and cycle time at the output shaft. A conveyor carrying uneven cartons may need brief torque peaks that a steady-load estimate misses. Small detail. Check the gearbox ratio and reflected inertia together; a higher ratio can increase output torque while slowing response.

Compare calculated performance with the motor-gearbox curves across the full duty cycle. Confirm continuous torque remains within rating after accounting for ambient temperature, mounting position, and cooling. Check output speed under load, not only unloaded speed. Accuracy also depends on backlash, torsional stiffness, encoder resolution, and control tuning. A few arcminutes of backlash may matter on a pick-and-place axis, but not on a simple feeder. Measure repeatability at the tool or load when possible. Numbers can look cleaner than the machine behaves.

Set safety margins for overload, shock, and temperature, using measured worst cases rather than optimistic averages. Allow headroom for starts, jams, and payload changes, without oversizing so much that low-speed control suffers. For vertical axes, verify brake holding torque and examine what happens during power loss. Margin is not a substitute for guarding. Document assumptions, then test the assembled axis under representative cycles; an early estimate will probably need revision.

FAQS

What information should I gather before sizing a geared servo motor?

Record output speed, acceleration time, duty cycle, and peak load torque. Rated speed alone is not enough.

How do I estimate the required torque?

Add load torque to inertia multiplied by angular acceleration. For 12 N·m, 0.018 kg·m², and 30 rad/s², output torque is about 12.54 N·m.

How does a 5:1 gearbox affect that example?

At 90% assumed efficiency, motor torque is roughly 2.8 N·m before motor and gearbox inertia. Check the ratio definition. Labels can confuse.

How should I reflect output inertia to the motor?

Divide output inertia by the ratio squared. Measure it. Include motor and gearbox inertia in the full calculation.

Which gearbox type suits different motion needs?

Planetary units suit compact, high-torque, low-backlash axes. Helical units run smoothly; worm units offer large reductions but often lower efficiency.

How do I choose a reduction ratio?

Match motor and output speeds; 3,000 rpm to 150 rpm suggests 20:1. Check torque after losses and verify continuous and peak ratings.

What affects positioning accuracy?

Check backlash, torsional stiffness, encoder resolution, and control tuning. Measure repeatability at the load. Catalog figures can look cleaner.

What should I test before approving the motor and gearbox?

Test representative starts, stops, brief overloads, and payload changes. Check loaded speed, temperature, vibration, and vertical-axis brake holding torque. Use measured worst cases for safety margins, then test the assembled axis.

Conclusion

Choosing a Geared Servo Motor starts with a clear understanding of the application’s motion profile and load, including required travel, acceleration, duty cycle, and external forces. These requirements help establish the necessary output torque and speed. Calculating reflected inertia is also essential, since the relationship between the motor and load affects responsiveness, stability, and overall performance.

Next, select a gearbox type and reduction ratio that balance output speed, torque, efficiency, and precision. Match the motor and drive to the expected operating conditions, such as the power supply, environment, and thermal demands. Finally, verify that the complete system can meet accuracy and repeatability targets while maintaining suitable margins for peak loads and unexpected variations. A thoughtful selection process helps ensure reliable motion, efficient operation, and a system that fits the application’s practical needs.
Mason

Mason

Mason is a seasoned marketing professional with a deep expertise in the company's offerings and a passion for driving brand awareness. With a strong background in digital marketing strategies, he has an innate ability to connect with diverse audiences and effectively communicate product benefits.......